<!doctype html>
<!-- This site was created with Hugo Blox. https://hugoblox.com -->
<!-- Last Published: June 11, 2026 --><html lang="en" dir="ltr"
      data-wc-theme-default="system">
  
<head>
  <meta charset="utf-8" />
  <meta name="viewport" content="width=device-width, initial-scale=1" />
  <meta http-equiv="X-UA-Compatible" content="IE=edge" />
  <meta name="generator" content="Hugo Blox Builder 0.3.1" />


  <meta name="description" content="Embodied Decision Large Model Research Group focuses on cutting-edge research in embodied intelligence, aiming to build a generalizable embodied agent through study in representation learning, policy learning, and hierarchical planning and execution.
" />

  
    <link rel="alternate" hreflang="zh" href="https://cs.nju.edu.cn/lm/research/embodied/index.html" />
  
  <link rel="alternate" hreflang="en" href="https://cs.nju.edu.cn/lm/en/research/embodied/index.html" />


    <link rel="stylesheet" href="/lm/css/themes/emerald.min.css" />


    <link href="/lm/dist/wc.min.css" rel="stylesheet" />


    <link href="/lm/css/custom.min.ea81ac527b7b68afaf466baf6a3ff09d750eb28d00742f4683ae6cf5a40d12e2.css" rel="stylesheet" />
  

  <script>
     
    window.hbb = {
       defaultTheme: document.documentElement.dataset.wcThemeDefault,
       setDarkTheme: () => {
        document.documentElement.classList.add("dark");
        document.documentElement.style.colorScheme = "dark";
      },
       setLightTheme: () => {
        document.documentElement.classList.remove("dark");
        document.documentElement.style.colorScheme = "light";
      }
    }

    console.debug(`Default Hugo Blox Builder theme is ${window.hbb.defaultTheme}`);

    if ("wc-color-theme" in localStorage) {
      localStorage.getItem("wc-color-theme") === "dark" ? window.hbb.setDarkTheme() : window.hbb.setLightTheme();
    } else {
      window.hbb.defaultTheme === "dark" ? window.hbb.setDarkTheme() : window.hbb.setLightTheme();
      if (window.hbb.defaultTheme === "system") {
        window.matchMedia("(prefers-color-scheme: dark)").matches ? window.hbb.setDarkTheme() : window.hbb.setLightTheme();
      }
    }
  </script>

  <script>
    
    document.addEventListener('DOMContentLoaded', function () {
      
      let checkboxes = document.querySelectorAll('li input[type=\'checkbox\'][disabled]');
      checkboxes.forEach(e => {
        e.parentElement.parentElement.classList.add('task-list');
      });

      
      const liNodes = document.querySelectorAll('.task-list li');
      liNodes.forEach(nodes => {
        let textNodes = Array.from(nodes.childNodes).filter(node => node.nodeType === 3 && node.textContent.trim().length > 1);
        if (textNodes.length > 0) {
          const span = document.createElement('label');
          textNodes[0].after(span);  
          span.appendChild(nodes.querySelector('input[type=\'checkbox\']'));
          span.appendChild(textNodes[0]);
        }
      });
    });
  </script>


  <link rel="icon" type="image/png" href="/lm/media/icon_hu_ffe66c26e9f445c8.png" />
  <link rel="apple-touch-icon" type="image/png" href="/lm/media/icon_hu_13320e5a3e063c33.png" />

  <link rel="canonical" href="https://cs.nju.edu.cn/lm/en/research/embodied/index.html" />


  <meta property="twitter:card" content="summary_large_image" />
  
    <meta property="twitter:site" content="@GetResearchDev" />
    <meta property="twitter:creator" content="@GetResearchDev" />
  
  <meta property="og:site_name" content="南京大学大模型研究协同创新中心" />
  <meta property="og:url" content="https://cs.nju.edu.cn/lm/en/research/embodied/index.html" />
  <meta property="og:title" content="Embodied Decision Large Model Research Group | 南京大学大模型研究协同创新中心" />
  <meta property="og:description" content="Embodied Decision Large Model Research Group focuses on cutting-edge research in embodied intelligence, aiming to build a generalizable embodied agent through study in representation learning, policy learning, and hierarchical planning and execution." /><meta property="og:image" content="https://cs.nju.edu.cn/lm/research/embodied/featured.jpg" />
    <meta property="twitter:image" content="https://cs.nju.edu.cn/lm/research/embodied/featured.jpg" /><meta property="og:locale" content="en" />
  
    
      <meta
        property="article:published_time"
        content="1017-01-01T00:00:00&#43;00:00"
      />
    
    <meta property="article:modified_time" content="1017-01-01T00:00:00&#43;00:00">


  <title>Embodied Decision Large Model Research Group | 南京大学大模型研究协同创新中心</title>


  <style>
    @font-face {
      font-family: 'Inter var';
      font-style: normal;
      font-weight: 100 900;
      font-display: swap;
      src: url(/lm/dist/font/Inter.var.woff2) format(woff2);
    }
  </style>


  <link type="text/css" rel="stylesheet" href="/lm/dist/lib/katex/katex.min.505d5f829022bb7b4f24dfee0aa1141cd7bba67afe411d1240335f820960b5c3.css" integrity="sha256-UF1fgpAiu3tPJN/uCqEUHNe7pnr&#43;QR0SQDNfgglgtcM=" />
  
  
  <script defer src="/lm/dist/lib/katex/katex.min.dc84b296ec3e884de093158f760fd9d45b6c7abe58b5381557f4e138f46a58ae.js" integrity="sha256-3ISyluw&#43;iE3gkxWPdg/Z1Ftser5YtTgVV/ThOPRqWK4="></script>


  <script defer src="/lm/js/katex-renderer.6579ec9683211cfb952064aedf3a3baea5eeb17a061775b32b70917474637c80.js" integrity="sha256-ZXnsloMhHPuVIGSu3zo7rqXusXoGF3WzK3CRdHRjfIA="></script>


  <script
    defer
    src="/lm/js/hugo-blox-en.min.8c8ea06bd0420f5067e52fa727b9f92303757322ba4431774153d59a9735eadb.js"
    integrity="sha256-jI6ga9BCD1Bn5S&#43;nJ7n5IwN1cyK6RDF3QVPVmpc16ts="
  ></script>


      <script async defer src="https://buttons.github.io/buttons.js"></script>


</head>

  <body class="dark:bg-hb-dark dark:text-white page-wrapper" id="top">
    <div id="page-bg"></div>
    <div class="page-header sticky top-0 z-30">


          <header id="site-header" class="header">
  <nav class="navbar px-3 flex justify-left">
    <div class="order-0 h-100">
      
      <a class="navbar-brand" href="/lm/en/index.html" title="南京大学大模型研究协同创新中心">


              <img
                fetchpriority="high"
                decoding="async"
                class=""
                width="36"
                height="36"
                src="/lm/media/icons/nju-emblem-cs_hu_ddcd3ca109e21c18.png"
                alt="南京大学大模型研究协同创新中心" />


        <span class="max-lg:hidden">Large Model Innovation Center</span>
      </a>
    </div>
    
    <input id="nav-toggle" type="checkbox" class="hidden" />
    <label
      for="nav-toggle"
      class="order-3 cursor-pointer flex items-center lg:hidden text-dark dark:text-white lg:order-1">
      <svg id="show-button" class="h-6 fill-current block" viewBox="0 0 20 20">
        <title>Open Menu</title>
        <path d="M0 3h20v2H0V3z m0 6h20v2H0V9z m0 6h20v2H0V0z"></path>
      </svg>
      <svg id="hide-button" class="h-6 fill-current hidden" viewBox="0 0 20 20">
        <title>Close Menu</title>
        <polygon
          points="11 9 22 9 22 11 11 11 11 22 9 22 9 11 -2 11 -2 9 9 9 9 -2 11 -2"
          transform="rotate(45 10 10)"></polygon>
      </svg>
    </label>


    <ul
      id="nav-menu"
      class="navbar-nav order-3 hidden lg:flex w-full pb-6 lg:order-1 lg:w-auto lg:space-x-2 lg:pb-0 xl:space-x-8 justify-left
      ">


        <li class="nav-item">
          <a
            class="nav-link "
            
            href="/lm/en/index.html"
          >Home</a
          >
        </li>


        <li class="nav-item">
          <a
            class="nav-link "
            
            href="/lm/en/post/index.html"
          >News</a
          >
        </li>


        <li class="nav-item">
          <a
            class="nav-link "
            
            href="/lm/en/research/index.html"
          >Research</a
          >
        </li>


        <li class="nav-item">
          <a
            class="nav-link "
            
            href="/lm/en/publication/index.html"
          >Publication</a
          >
        </li>


    </ul>

    <div class="order-1 ml-auto flex items-center md:order-2 lg:ml-0">


      <div class="px-3 text-black hover:text-primary-700 dark:text-white dark:hover:text-primary-300
            [&.active]:font-bold [&.active]:text-black/90 dark:[&.active]:text-white">
        <button class="theme-toggle mt-1" accesskey="t" title="appearance">
          <svg id="moon" xmlns="http://www.w3.org/2000/svg" width="24" height="18" viewBox="0 0 24 24"
               fill="none" stroke="currentColor" stroke-width="2" stroke-linecap="round"
               stroke-linejoin="round" class="dark:hidden">
            <path d="M21 12.79A9 9 0 1 1 11.21 3 7 7 0 0 0 21 12.79z"></path>
          </svg>
          <svg id="sun" xmlns="http://www.w3.org/2000/svg" width="24" height="18" viewBox="0 0 24 24"
               fill="none" stroke="currentColor" stroke-width="2" stroke-linecap="round"
               stroke-linejoin="round" class=" dark:block [&:not(dark)]:hidden">
            <circle cx="12" cy="12" r="5"></circle>
            <line x1="12" y1="1" x2="12" y2="3"></line>
            <line x1="12" y1="21" x2="12" y2="23"></line>
            <line x1="4.22" y1="4.22" x2="5.64" y2="5.64"></line>
            <line x1="18.36" y1="18.36" x2="19.78" y2="19.78"></line>
            <line x1="1" y1="12" x2="3" y2="12"></line>
            <line x1="21" y1="12" x2="23" y2="12"></line>
            <line x1="4.22" y1="19.78" x2="5.64" y2="18.36"></line>
            <line x1="18.36" y1="5.64" x2="19.78" y2="4.22"></line>
          </svg>
        </button>
      </div>


      <div id="language-chooser-container" class="pl-1 mr-5 text-gray-600 hover:text-gray-800 dark:text-gray-400 dark:hover:text-gray-200
            [&.active]:font-bold [&.active]:text-black/90 dark:[&.active]:text-white">


<div class="flex justify-items-start ">
    <button
      title="Languages"
      data-state="closed"
      data-hb-language-chooser
      class="grow h-7 rounded-md px-2 text-left text-xs font-medium text-gray-600 transition-colors dark:text-gray-400 hover:bg-gray-100 hover:text-gray-900 dark:hover:bg-primary-100/5 dark:hover:text-gray-50"
      type="button"
      aria-label="Languages"
    >
      <div class="flex items-center gap-2 capitalize">
        <svg height=18 xmlns="http://www.w3.org/2000/svg" viewBox="0 0 24 24"><path fill="none" stroke="currentColor" stroke-linecap="round" stroke-linejoin="round" stroke-width="1.5" d="m10.5 21l5.25-11.25L21 21m-9-3h7.5M3 5.621a48.474 48.474 0 0 1 6-.371m0 0c1.12 0 2.233.038 3.334.114M9 5.25V3m3.334 2.364C11.176 10.658 7.69 15.08 3 17.502m9.334-12.138A47.63 47.63 0 0 1 15 5.621m-4.589 8.495a18.023 18.023 0 0 1-3.827-5.802"/></svg><span>English</span></div>
    </button>
    <ul
      class="fixed m-0 min-w-[100px] hidden z-20 max-h-64 overflow-auto rounded-md ring-1 ring-black/5 bg-white py-1 text-sm shadow-lg dark:ring-white/20 dark:bg-neutral-800"
      style="inset: auto auto 0 0;"
    >
      
        <li class="flex flex-col">
          <a
            href="https://cs.nju.edu.cn/lm/research/embodied/index.html"
            class="relative cursor-pointer text-gray-800 dark:text-gray-100 hover:bg-primary-50 hover:text-primary-600 hover:dark:bg-primary-500/10 hover:dark:text-primary-200 whitespace-nowrap py-1.5 transition-colors ltr:pl-3 ltr:pr-9 rtl:pr-3 rtl:pl-9"
          >中文 (简体)</a>
        </li>
      </ul>
  </div></div>


    </div>
  </nav>
</header>


    </div>
    <div class="page-body ">


<section id="section-markdown" class="relative hbb-section blox-markdown  " style="padding: 1rem 0 1rem 0;" >
 <div class="home-section-bg " >
   
 </div>


<div class="flex flex-col items-center max-w-prose mx-auto gap-3 justify-center px-6">

  <div class="prose prose-slate dark:prose-invert max-w-prose">
    <h3 class="mb-6 font-bold" style="margin-bottom: 1.5rem;">
      
    </h3>
  </div>

  
  <div class="prose prose-slate dark:prose-invert max-w-prose"><h2 id="embodied-decision-large-model-research-group">Embodied Decision Large Model Research Group</h2>
</div>
</div>


</section>


<section id="members" class="relative hbb-section blox-collection  " style="padding: 1rem 0 1rem 0;" >
 <div class="home-section-bg " >
   
 </div>


<div class="flex flex-col items-center max-w-prose mx-auto gap-3 justify-center px-6 md:px-0">

  <div class="prose prose-slate dark:prose-invert max-w-prose">
    <h3 class="font-bold">
      Team Members
    </h3>
  </div>

  
</div>


<div class="flex flex-col items-center px-6">


<div class="container px-8 mx-auto xl:px-5 py-5 lg:py-8 max-w-[500px] justify-center">
  <div class="grid gap-10 md:grid-cols-1 lg:gap-10">


<div class="resume-biography flex justify-center items-center flex-col">
  <div class="avatar-wrapper mt-5">
    
    <img class="avatar rounded-full bg-white dark:bg-gray-800 p-1" src="/lm/authors/limin-wang/avatar_hu_2c994ba34a2cc472.png" alt="Limin Wang"
          width="150" height="150">
    
  </div>

  <div class="portrait-title dark:text-white" style="text-align: center;">

    <div class="text-2xl font-bold mb-2 mt-6"><a href="https://wanglimin.github.io" target="_blank" rel="noopener">Limin Wang</a></div>

    <h3 class="font-semibold mb-1"><a href='https://www.nju.edu.cn'>Nanjing University</a></h3>

    
    <div class="mb-2">
      <a href="https://cs.nju.edu.cn" target="_blank" rel="noopener">
      <div>School of Computer Science</div>
      </a>
    </div>
    
  </div>

  <ul class="network-icon dark:text-zinc-100">


    <li class="mt-1 mb-1">
      <a href="mailto:lmwang@nju.edu.cn"  aria-label="at-symbol"
           data-toggle="tooltip" data-placement="top" title="E-mail Me">
        <svg style="height: 1.5rem;" xmlns="http://www.w3.org/2000/svg" viewBox="0 0 24 24"><path fill="none" stroke="currentColor" stroke-linecap="round" stroke-width="1.5" d="M16.5 12a4.5 4.5 0 1 1-9 0a4.5 4.5 0 0 1 9 0Zm0 0c0 1.657 1.007 3 2.25 3S21 13.657 21 12a9 9 0 1 0-2.636 6.364M16.5 12V8.25"/></svg>
      </a>
    </li>
    
  </ul>
</div>
  

    </div>
</div>


</div>


</section>


<section id="section-markdown" class="relative hbb-section blox-markdown  " style="padding: 1rem 0 1rem 0;" >
 <div class="home-section-bg " >
   
 </div>


<div class="flex flex-col items-center max-w-prose mx-auto gap-3 justify-center px-6">

  <div class="prose prose-slate dark:prose-invert max-w-prose">
    <h3 class="mb-6 font-bold" style="margin-bottom: 1.5rem;">
      Overview of Key Achievements
    </h3>
  </div>

  
  <div class="prose prose-slate dark:prose-invert max-w-prose"><p>The Embodied Decision Large Model Research Group focuses on cutting-edge research in embodied intelligence. Our research aims to build a generalizable embodied agent with investigations in embodied representation learning, policy learning, and hierarchical planning and execution. Below are some representative achievements:</p>
<h3 id="representative-achievement-1-stp--a-spatiotemporal-predictive-visual-representation-pre-training-model-for-robotic-motor-control">Representative Achievement 1: STP – A Spatiotemporal Predictive Visual Representation Pre-training Model for Robotic Motor Control</h3>
<p>


<figure  >
  <div class="flex justify-center	">
    <div class="w-100" ><img alt="STP" srcset="
               /lm/research/embodied/stp_hu_bed7c1c7cc36d404.jpg 400w,
               /lm/research/embodied/stp_hu_4bd45fef577e14c4.jpg 760w,
               /lm/research/embodied/stp_hu_5e5fb2aac3eceb1e.jpg 1200w"
               src="/lm/research/embodied/stp_hu_bed7c1c7cc36d404.jpg"
               width="760"
               height="355"
               loading="lazy" data-zoomable /></div>
  </div></figure>
</p>
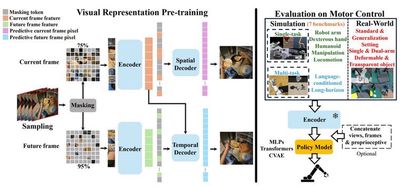
<p>This work leverages a large-scale human first-person manipulation video dataset and employs decoupled spatial and temporal predictions as self-supervised proxy tasks to propose the image representation model STP dedicated for robotic motion control. The pre-trained STP model can be directly transferred to various robotic control tasks without fine-tuning and has outperformed existing baselines in over 50 tasks across real and seven simulated environments. These tasks include operations of single robotic arms, dual robotic arms, three-fingered dexterous hands, five-fingered dexterous hands, as well as humanoid robots.</p>
<p>Related papers:</p>
<p>Jiange Yang, Bei Liu, Jianlong Fu, Bocheng Pan, Gangshan Wu, Limin Wang, <a href="https://arxiv.org/abs/2403.05304" target="_blank">Spatiotemporal Predictive Pre-training for Robotic Motor Control</a>.</p>
<h3 id="representative-achievement-2-spa--a-3d-rendering-driven-visual-representation-pre-training-model-for-embodied-intelligence">Representative Achievement 2: SPA – A 3D Rendering Driven Visual Representation Pre-training Model for Embodied Intelligence</h3>
<p>


<figure  >
  <div class="flex justify-center	">
    <div class="w-100" ><img alt="SPA" srcset="
               /lm/research/embodied/spa_hu_5d390150238fabbc.jpg 400w,
               /lm/research/embodied/spa_hu_f45579c87f0edec2.jpg 760w,
               /lm/research/embodied/spa_hu_d57d47a043d28ab6.jpg 1200w"
               src="/lm/research/embodied/spa_hu_5d390150238fabbc.jpg"
               width="760"
               height="319"
               loading="lazy" data-zoomable /></div>
  </div></figure>
</p>
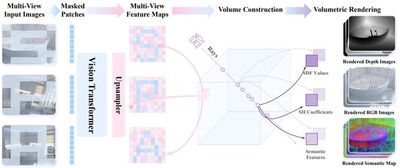
<p>In this work, we propose a visual representation learning framework, SPA, which enhances 3D spatial awareness to improve representation learning in embodied intelligence tasks. SPA constructs a large-scale multi-view dataset with camera poses, depth maps, and semantic feature annotations by synthesizing indoor scenes and real-world robot interaction scenarios. It then builds 3D volumetric features from multi-view images and camera poses, and uses masking techniques along with differentiable neural rendering to generate RGB images, depth maps, and semantic maps. Additionally, Eikonal regularization and SDF supervision further improve 3D geometric consistency. Trained for 6000 GPU hours, SPA achieves superior average performance over other baseline methods across more than 200 tasks in both real environments and eight simulated settings, ranking first in up to 30.3% of the tasks.</p>
<p>Related papers:</p>
<p>Haoyi Zhu, Honghui Yang, Yating Wang, Jiange Yang, Limin Wang, Tong He, <a href="https://arxiv.org/abs/2410.08208" target="_blank">SPA: 3D Spatial-Awareness Enables Effective Embodied Representation</a>, in ICLR 2025.</p>
<h3 id="representative-achievement-3-tra-moe--an-embodied-trajectory-prediction-and-decision-model-driven-by-multi-domain-data-learning">Representative Achievement 3: Tra-MoE – An Embodied Trajectory Prediction and Decision Model Driven by Multi-domain Data Learning</h3>
<p>


<figure  >
  <div class="flex justify-center	">
    <div class="w-100" ><img alt="Tra-MoE" srcset="
               /lm/research/embodied/tramoe_hu_265be854d89b444c.jpg 400w,
               /lm/research/embodied/tramoe_hu_4dfe95d95ed6ddf9.jpg 760w,
               /lm/research/embodied/tramoe_hu_9421835071d69dd9.jpg 1200w"
               src="/lm/research/embodied/tramoe_hu_265be854d89b444c.jpg"
               width="760"
               height="454"
               loading="lazy" data-zoomable /></div>
  </div></figure>
</p>
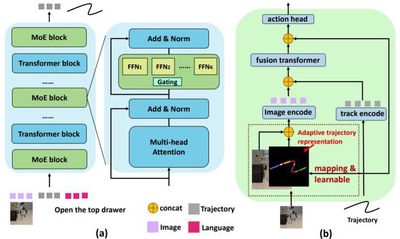
<p>This work introduces Tra-MoE, a trajectory prediction model based on a sparsely gated mixture-of-experts architecture. By balancing parameter collaboration and specialization, Tra-MoE learns a more generalizable trajectory prediction model from large-scale, multi-domain, unlabeled video data, surpassing dense baselines of equivalent parameter scale. It effectively integrates simulation videos rendered by diverse physics engines with real-world manipulation videos involving humans, single robotic arms, and dual robotic arms. Furthermore, the work proposes an adaptive policy-conditioning method that leverages predicted trajectories to guide robotic policies, significantly enhancing downstream performance.</p>
<p>Related papers:</p>
<p>Jiange Yang, Haoyi Zhu, Yating Wang, Gangshan Wu, Tong He, Limin Wang, <a href="https://arxiv.org/abs/2411.14519" target="_blank">Learning Trajectory Prediction Model from Multiple Domains for Adaptive Policy Conditioning</a>, in CVPR 2025.</p>
<h3 id="representative-achievement-4-a-generalizable-hierarchical-planning-and-execution-framework-and-system">Representative Achievement 4: A Generalizable Hierarchical Planning and Execution Framework and System</h3>
<p>


<figure  >
  <div class="flex justify-center	">
    <div class="w-100" ><img alt="TPM" srcset="
               /lm/research/embodied/tpm_hu_56213a5db7e0a6ea.jpg 400w,
               /lm/research/embodied/tpm_hu_25195f7a84a0f258.jpg 760w,
               /lm/research/embodied/tpm_hu_1ed20a5633dfc71d.jpg 1200w"
               src="/lm/research/embodied/tpm_hu_56213a5db7e0a6ea.jpg"
               width="760"
               height="335"
               loading="lazy" data-zoomable /></div>
  </div></figure>
</p>
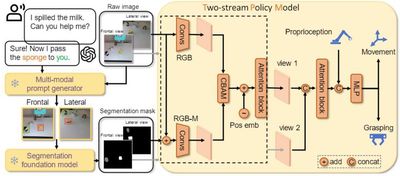
<p>Although vision-language models trained on internet-scale data achieve impressive generalization across various tasks, their inability to interact with the real world limits their physical understanding. Conversely, robotic policies trained via imitation learning capture skills from human demonstrations; however, high data collection costs and homogenization hinder robust generalization. This work integrates a masked modality from language reasoning into an end-to-end policy model to enable sample-efficient generalization in robotic manipulation. By fusing semantic, geometric, and temporal priors inherent in internet foundational models with the diversity captured through imitation learning, the proposed approach bridges perception, reasoning, planning, and decision-making. It has been cited by teams from Stanford (Fei-Fei Li) and UC Berkeley (Jitendra Malik), and its hierarchical scheme is also adopted by leading embodied intelligence companies like Figure AI and Physical Intelligence.</p>
<p>Related papers:</p>
<p>Jiange Yang, Wenhui Tan, Chuhao Jin, Keling Yao, Bei Liu, Jianlong Fu, Ruihua Song, Gangshan Wu, Limin Wang, <a href="https://arxiv.org/abs/2306.05716" target="_blank">Transferring Foundation Models for Generalizable Robotic Manipulation</a>, in WACV 2025 Oral.</p>
</div>
</div>


</section>


    </div>
    <div class="page-footer">
      <footer class="container mx-auto flex flex-col justify-items-center text-sm leading-6 mt-24 mb-4 text-slate-700 dark:text-slate-200">


<div class="mx-auto flex gap-3 py-2 px-4">
  <div class="font-bold"><svg class="inline-block pr-1" style="height: 1em" xmlns="http://www.w3.org/2000/svg" viewBox="0 0 24 24"><path fill="none" stroke="currentColor" stroke-linecap="round" stroke-linejoin="round" stroke-width="1.5" d="M12 21a9.004 9.004 0 0 0 8.716-6.747M12 21a9.004 9.004 0 0 1-8.716-6.747M12 21c2.485 0 4.5-4.03 4.5-9S14.485 3 12 3m0 18c-2.485 0-4.5-4.03-4.5-9S9.515 3 12 3m0 0a8.997 8.997 0 0 1 7.843 4.582M12 3a8.997 8.997 0 0 0-7.843 4.582m15.686 0A11.953 11.953 0 0 1 12 10.5c-2.998 0-5.74-1.1-7.843-2.918m15.686 0A8.959 8.959 0 0 1 21 12c0 .778-.099 1.533-.284 2.253m0 0A17.919 17.919 0 0 1 12 16.5a17.92 17.92 0 0 1-8.716-2.247m0 0A9.015 9.015 0 0 1 3 12c0-1.605.42-3.113 1.157-4.418"/></svg>Languages:
  </div>
  <div class="font-bold">English</div>
  
  <div><a href="https://cs.nju.edu.cn/lm/research/embodied/index.html">中文 (简体)</a></div>
  
</div>


  <p class="powered-by text-center">
    © 2026 Large Model Innovation Center, Nanjing University. This work is licensed under <a href="https://creativecommons.org/licenses/by-nc-nd/4.0" rel="noopener noreferrer" target="_blank">CC BY NC ND 4.0</a>
  </p>
  

  <p class="powered-by footer-license-icons">
    <a href="https://creativecommons.org/licenses/by-nc-nd/4.0" rel="noopener noreferrer" target="_blank" aria-label="Creative Commons">
      <i class="fab fa-creative-commons fa-2x" aria-hidden="true"></i>
      <i class="fab fa-creative-commons-by fa-2x" aria-hidden="true"></i>
      
        <i class="fab fa-creative-commons-nc fa-2x" aria-hidden="true"></i>
      
      
        <i class="fab fa-creative-commons-nd fa-2x" aria-hidden="true"></i>
      
    </a>
  </p>


  <p class="powered-by text-center">


      Published with <a href="https://hugoblox.com/?utm_campaign=poweredby" target="_blank" rel="noopener">Hugo Blox Builder</a> — the free, <a href="https://github.com/HugoBlox/hugo-blox-builder" target="_blank" rel="noopener">open source</a> website builder that empowers creators.
    
  </p>

</footer>

    </div>


      <script src="https://cdn.staticfile.net/typed.js/2.1.0/typed.umd.min.js"></script>
<script>
    var element = document.getElementById('typed');
    var text = element ? element.innerText : '';
    element.innerHTML = '';
    var typed = new Typed('#typed', {
        strings: [text],
        typeSpeed: 100,
        showCursor: false,
    });
</script>


  </body>
</html>